






A robot gripper is the end effector on a robot arm that grasps, holds, and releases parts. Most robot grippers run on compressed air, an electric servo motor, vacuum, hydraulic pressure, or magnets. They hold parts with two jaws, three jaws, suction cups, or soft fingers. You choose one by part weight, grip force, part shape, and the environment it works in.
That covers the basics. One point most guides skip: for CNC machine tending, a gripper does not always need a robot arm. A spindle gripper can live in the tool changer and use the machine's own axes to move parts. We cover both routes below, along with the sizing math, real 2026 prices, and how to tell which one fits your shop.
What Is a Robot Gripper?
A robot gripper is a device that bolts to the end of a robot arm so the robot can pick up, hold, move, and release objects. It is a type of end effector, the general name for any tool on the end of the arm. The gripper is the only part of the robot that touches your part. That makes it the part that decides whether parts arrive clean, square, and on time.
Grippers mount to the arm's tool flange. Most industrial arms follow the ISO 9409-1 bolt pattern for that flange, so a gripper usually needs only an adapter plate to fit a given robot. Many cells add a quick changer between the two. That lets the robot swap grippers between jobs without a wrench.
In gripper robotics, the arm gets most of the attention. The gripper does most of the work that matters to the part.
Gripper vs End Effector vs EOAT
These three terms get mixed up constantly. Here is how they relate.
| Term | What it covers | Examples |
|---|---|---|
| End effector | Any tool on the end of a robot arm | Welding torch, spray gun, screwdriver, gripper |
| EOAT (end-of-arm tooling) | Industry term for the same scope as end effector, often including mounts and quick changers | Gripper plus adapter plate plus tool changer |
| Robot gripper | The subset of end effectors that hold parts | Parallel jaw gripper, vacuum cup, magnetic gripper |
So every gripper is an end effector, but not every end effector is a gripper. With the vocabulary sorted, the next question is what is inside one.
How a Robot Gripper Works: The Core Components

Picture a two-jaw air gripper closing on an aluminum blank. Air enters a cylinder, a piston moves, and a mechanism turns that push into jaw travel. Sensors confirm the jaws closed. Then the robot moves. Every gripper type follows some version of that chain.
Actuator
The actuator supplies the force. In a pneumatic gripper it is a piston driven by compressed air. In an electric gripper it is a servo or stepper motor. Hydraulic grippers use a cylinder fed by oil pressure. Vacuum grippers use a pump or a venturi generator to pull air out from under a suction cup.
Drive mechanism
The drive mechanism converts actuator motion into jaw motion and keeps the jaws in sync. A wedge or cam design gives high force in a short stroke. Rack and pinion designs give longer strokes. Linkages are common in angular grippers, where the jaws pivot instead of slide.
Jaws and fingers
Base jaws are part of the gripper body. Fingers bolt onto the base jaws and do the actual holding. Fingers are where most of the custom work happens: shaped to the part, padded with rubber, or machined as soft jaws. They also wear, so plan on replacing them.
Sensors and feedback
Simple grippers use magnetic sensors that read jaw position. More advanced units add part-present sensors, force and torque sensing, or tactile pads. The goal is the same for all of them: confirm the part is held before the robot moves.
Air, power, and signal routing
Pneumatic grippers need an air supply, a solenoid valve, and an output signal to fire that valve. Electric grippers need power and a control cable. Rotating wrists may need a rotary union so hoses do not wind up. Bad routing causes more downtime than the gripper itself.
Those five parts show up in every design. What changes between types is the power source and how the part is held.
Types of Robot Grippers
Robot grippers sort two ways: by power source and by jaw layout. Most real grippers are a mix of both, such as a pneumatic two-jaw parallel gripper. Start with the power source, because it sets force, speed, cost, and what utilities you need.
| Type | Power source | Force control | Best for | Main limit |
|---|---|---|---|---|
| Pneumatic | Compressed air | Set by air pressure | Fast, repeat pick and place, machine tending | Jaws travel end to end; needs clean, dry air |
| Electric (servo) | Electric motor | Programmable force, speed, position | Mixed parts, delicate assembly, no air on site | Higher cost, lower force per size |
| Vacuum | Pump or venturi | Set by vacuum level and cup size | Flat, smooth, non-porous parts | Porous, oily, or textured surfaces leak |
| Magnetic | Electromagnet or permanent magnet | On/off or adjustable current | Steel sheet and ferrous parts | Ferrous only, residual magnetism |
| Hydraulic | Oil pressure | Set by pressure | Very heavy parts | Leaks, hoses, maintenance |
| Soft / adaptive | Air, vacuum, or motor | Low, shape-conforming | Food, produce, irregular shapes | Low precision, low force |

Pneumatic Grippers for Robots
Pneumatic grippers are the most common industrial choice. Compressed air drives a piston, and the piston drives the jaws. They are compact, fast, and strong for their size. They also cost less than electric grippers of the same force.
A few details matter more than most buyers expect:
- Check single vs double acting. Double-acting grippers use air to open and close. Single-acting grippers use air one way and a spring the other.
- Know the default state. A normally open gripper opens when air is off. A normally closed gripper holds the part when air is off.
- Plan for air loss. Spring assist keeps grip force on the part if pressure drops. That protects the part and the people near it.
- Use the regulator to set force. Standard pneumatic jaws travel end to end, but grip force scales with supply pressure. Turn the pressure down for thin walls. Turn it up for heavy blanks.
That last point clears up a common myth. Pneumatic grippers are on/off in position, not in force. For a deeper look at air-powered designs, see our guide to pneumatic grippers.
Electric (Servo-Electric) Grippers
Electric grippers use a motor and a controller. You can program jaw position, speed, and force for each part. They need no air line, which helps in clean rooms and shops without good compressed air.
The tradeoff is cost and force density. You pay more for a given grip force, and the body is often larger. We break down where each one wins in our pneumatic vs electric gripper guide.
Vacuum Grippers
Vacuum grippers hold parts with suction cups or foam pads. A pump or a venturi generator pulls air out, and outside air pressure pushes the part against the cup. They work best on flat, smooth, non-porous surfaces like glass, sheet metal, and machined faces.
One claim you will see often is that vacuum grippers do not touch the part. They do. The cup sits on the surface. What they avoid is jaw pressure on the sides of the part. Coolant film, porous castings, and rough stock all break the seal.
Magnetic Grippers
Magnetic grippers use an electromagnet, a permanent magnet, or an electro-permanent magnet to hold steel. The pole face contacts the part. They are fast and simple for sheet metal and steel blanks.
Their disadvantages are real:
- They only work on ferrous parts. Aluminum, brass, and plastic are out.
- Parts can keep residual magnetism, which attracts chips later.
- Thin sheets can stick together, so the gripper picks two instead of one.
- In a machine shop, they pick up chips and swarf.
Hydraulic Grippers
Hydraulic grippers deliver the highest force for their size. Heavy forgings, castings, and large steel parts are their home. The cost is complexity: hydraulic power units, hoses, seals, and the risk of oil leaks near the part. Most cells only use them when air and electric grippers cannot reach the required force.
Soft, Adaptive, and Jamming Grippers
Soft grippers use flexible silicone fingers that bend around the part. Adaptive grippers use linked finger segments that wrap a shape without sensors. Both handle food, produce, and odd shapes well.
Jamming grippers are a clever variant. A flexible bag filled with granular material presses onto the part and flows around it. Then a vacuum pulls the air out, the grains lock together, and the bag hardens into a custom grip. Researchers showed this in 2010, and they found it took less than a 0.5% change in volume to grip reliably. Some sources say jamming grippers work by adding air pressure. That has it backward: vacuum does the gripping.
None of these suit machining loads. They trade precision and force for flexibility.
Grippers by Jaw Configuration
The jaw layout decides what shapes a gripper can hold well.
- Two-jaw parallel grippers. Jaws slide toward each other in a straight line. They are the default for square and rectangular parts, and they center the part between the jaws. See our overview of parallel grippers.
- Three-jaw concentric grippers. Three jaws close on a center point, like a lathe chuck. Best for round bar, shafts, and cylinders.
- Angular grippers. Jaws pivot open and closed. They are compact and fast, but they center the part less precisely as size changes.
- Multi-finger hands. Four or five fingers with many joints. Mostly research and humanoid robots for now.
Once the type is chosen, the job decides the details. Here is where each type tends to win.
Robotic Arm Gripper Applications
Most robotic arm gripper work falls into a few jobs. Each one tends to favor a type.
| Application | What the gripper does | Usual winner |
|---|---|---|
| Pick and place | Moves parts between conveyors, trays, and fixtures | Pneumatic parallel or vacuum |
| Palletizing and packaging | Stacks boxes and bags | Vacuum or fork-style grippers |
| Assembly | Places parts with controlled force | Electric grippers |
| Machine tending | Loads and unloads CNC mills and lathes | Pneumatic parallel or three-jaw |
| Food, lab, and pharma | Handles soft or sterile items | Soft or electric grippers |
Machine tending is where a gripper robot earns its keep in a machine shop. It is also where the robot arm turns out to be optional, which we get to after sizing.
How to Choose a Robot Gripper
Most gripper problems trace back to sizing. The gripper was too weak for the move, the stroke was too short for the part range, or the robot ran out of payload. Work through these in order.
Payload budget
The robot's rated payload must cover the gripper, the fingers, the adapter plate, the quick changer, and the part. Then it must handle the speed you plan to move at. An offset center of gravity adds a moment load on the wrist, which lowers what the arm can carry. A heavy gripper on a small arm leaves very little room for the part.
Grip force: the math
This is the step most guides skip, and it is the one that drops parts.
For a friction grip, where flat jaws squeeze the part, the jaws must create enough friction to hold the part's weight plus a safety margin:
Required grip force ≥ (part weight × safety factor) ÷ friction coefficient
Gripper makers commonly use a safety factor of 2 and a friction coefficient of 0.1 to 0.2 for metal jaws on metal parts. That works out to a simple rule:
- Normal moves: grip force of 10 to 20 times the part weight.
- Fast acceleration, hard stops, or impact: 30 to 50 times the part weight.
Worked example. A 4 lb aluminum block, moved at normal speed, needs 40 to 80 lbf of grip force. Move it fast with hard stops, and you need 120 to 200 lbf. Check whether the gripper's rated force is per jaw or total. Spec sheets differ.
Finger shape changes the math. Fingers that cradle the part, with a notch, a step, or a V, hold by form fit instead of pure friction. The geometry carries the load, so the gripper needs far less force. When we size grippers for heavier blanks, finger design is usually the first fix, before a bigger gripper.
Stroke and part size range
Stroke is how far each jaw travels. Make sure the open position clears your largest part with room for positioning error. Make sure the closed position still grips your smallest part. If you run a wide part range, longer-stroke grippers or quick-change fingers save setup time.
Part material, finish, and shape
Soft materials and finished surfaces mark easily under hard jaws. Use rubber pads, plastic fingers, or machined soft jaws. Round parts want three jaws or V-shaped fingers. Thin walls want lower pressure and more contact area.
Cycle time
Pneumatic grippers open and close in a fraction of a second. Electric grippers are often a bit slower but can be tuned. Over thousands of cycles a day, jaw time adds up, so include it when you estimate output.
Environment: coolant, chips, and washdown
Every competitor guide talks about cleanrooms. Few mention the place most grippers actually die in a machine shop: around coolant and chips. Coolant gets past weak seals. Chips pack into jaw slides. If the gripper works inside or near a CNC enclosure, look for sealed designs, a way to blow chips off, and fingers that are easy to clean or replace.
Controls and integration
On a robot, grippers connect through digital I/O, a fieldbus, or IO-Link. On a CNC, a pneumatic gripper usually fires from an M-code output to a solenoid valve. Confirm your controller has a free output before you buy.
Safety: what changed in 2025
The main industrial robot safety standard, ISO 10218, was revised and published in two parts in February 2025. The new Part 2 now includes most of the collaborative robot requirements that used to sit in ISO/TS 15066. It also folds in guidance on end effectors that used to live in separate technical reports. For gripper buyers, the practical result is simple: the gripper, the fingers, and the part are all part of the risk assessment. Ask what happens to the part when power or air drops.
Get these right and the gripper will do its job. How it is built to do that job is a design question.
Robot Gripper Design Basics
Good robot gripper design starts with the part, not the gripper. Designers look at a few things first.
- Finger length. Longer fingers reach more but create more leverage on the jaw guides. Keep them as short as the part allows.
- Jaw stroke. Enough to clear the part and the positioning error, and no more.
- Finger material. Steel for durability, aluminum for weight, plastic or rubber for finished surfaces.
- Compliance. A little give in the fingers or mount absorbs small position errors.
- Weight and center of gravity. Every ounce on the gripper comes off the robot's payload.
Each of these involves tradeoffs that deserve more space than one section. We cover finger geometry, force calculation, and jaw layouts in depth in our guide to robot gripper design.
Robot Gripper Kits: Hobby vs Industrial
"Robot gripper kit" means two very different things. One is a classroom or hobby claw for a small desktop arm. The other is an industrial gripper package that ships ready to bolt on and run.
Hobby and STEM kits use a small servo, plastic or aluminum claws, and a few ounces to a pound or so of grip. They are great for learning, prototyping, and Arduino or Raspberry Pi projects. They are not built for production duty.
Industrial kits bundle the gripper with what it takes to run. A complete kit should include:
- The gripper body, rated for your part weight and cycle count.
- Mounting hardware, such as an adapter plate, holder, or quick changer.
- Fingers or finger plates that adjust to several part sizes.
- Hoses, cables, or a valve kit to connect power and control.
- Control integration, such as a software plugin, I/O wiring, or M-code setup.
- Documentation and CAD so you can design custom fingers.
Our spindle grippers ship this way. Each GimGripper4™ comes as a ready-to-run kit with universal finger plates, several finger sets, and rubber compression pads. With the kit sorted, the next question is usually price.
How Much Does a Robot Gripper Cost?
Robot gripper prices span three orders of magnitude. Here is what new grippers listed for in October 2026 shopping results:
| Category | Typical listing price (Oct 2026) |
|---|---|
| Hobby or STEM claw and kits | About $9 to $85 |
| Desktop and educational arm grippers | About $120 to $800 |
| Industrial smart pneumatic parallel grippers | About $2,800 to $3,500 |
| Industrial electric two-finger grippers | About $2,800 to $8,400 |
| Three-finger, four-finger, and servo hands | About $6,700 to $32,800 |
The gripper is rarely the biggest cost. A working cell also needs the robot arm, a mounting base, guarding or safety scanners, integration labor, robot programming, and custom fingers. That full cell is what most shops actually pay for.
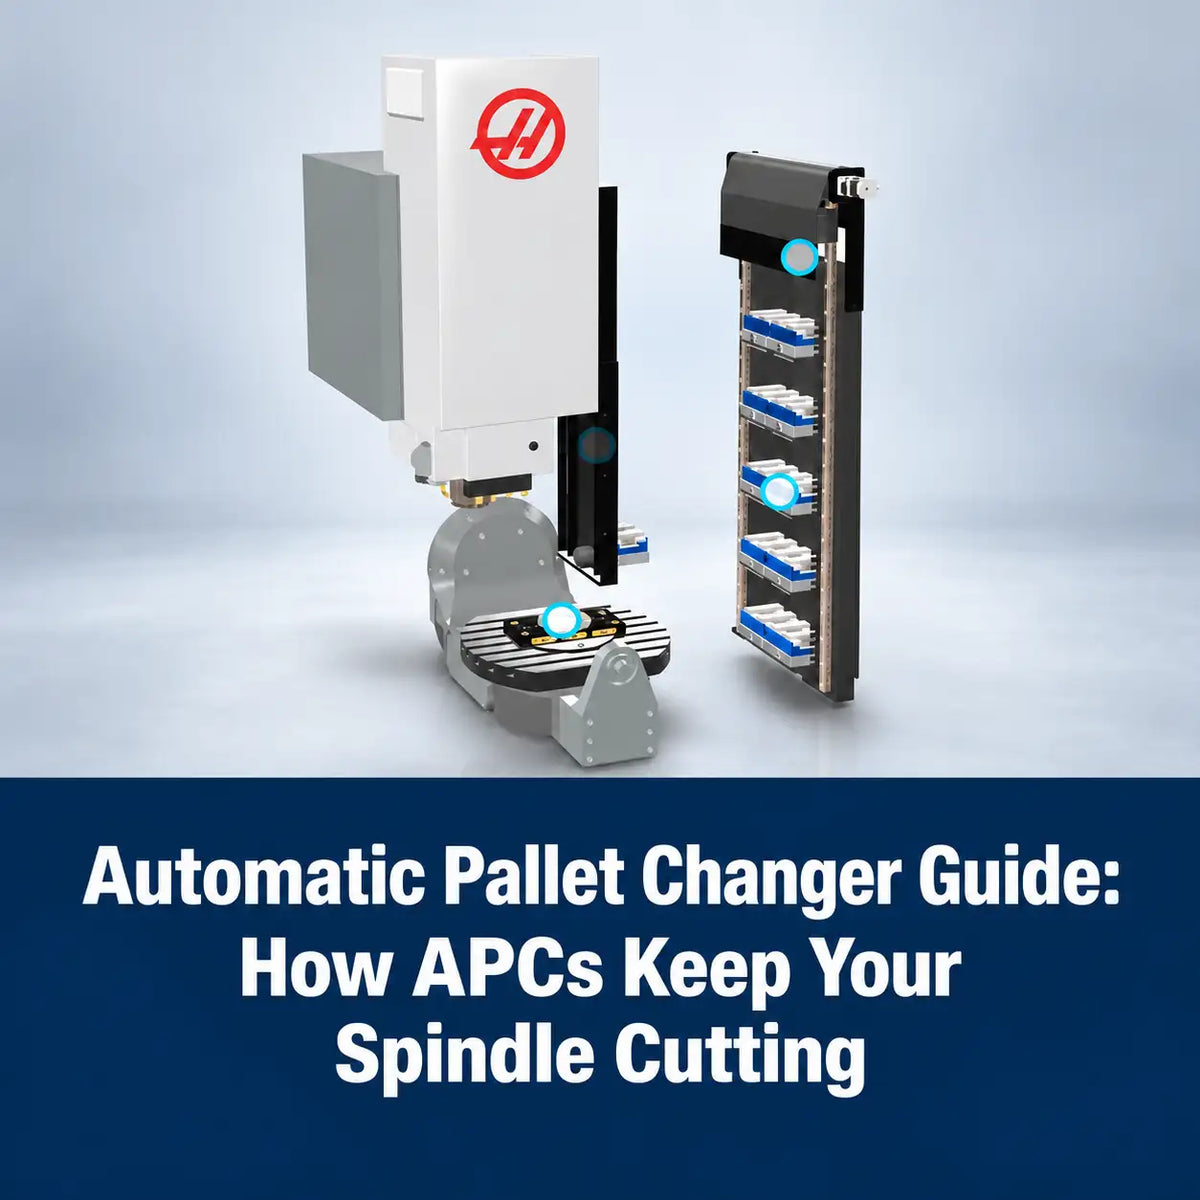
For CNC machine tending, there is a cheaper path. In-machine spindle grippers start at $1,379 and need no arm at all.
Robot Grippers for CNC Machine Tending: Robotic Arm vs In-Machine Spindle Gripper
A CNC mill already has precise, programmable motion in three or more axes. A robot arm adds a second motion system to move parts in and out of it. A spindle gripper skips that second system and uses the first.
How robot-cell machine tending works
A typical cell puts the robot on a base next to the machine. Raw parts sit on a table or drawer. The CNC finishes a cycle, the door opens, and the robot reaches in. It unloads the finished part, loads a blank into the vise or fixture, and backs out. The door closes and the cycle starts again. It takes a robot program, a signal handshake with the CNC, an automatic door, and guarding around the robot's reach.
How a spindle gripper works
A spindle gripper sits in the automatic tool changer like any other tool. When it is time to load, the machine calls it into the spindle. The machine's own axes move it over the blank, the fingers close, and the machine places the part in an automated vise. Then the gripper goes back to the tool changer and cutting starts.
Here is how our GimGripper4™ handles that, per its live product specs:
- It takes up one tool slot and works with almost all tool changers.
- The fingers are normally open and close on through-spindle air (TSA model) or through-spindle coolant (TSC model).
- Gripping is controlled by M-codes, so the load sequence is part of the G-code program. There is no robot program.
- Operating pressure range is 0 to 175 psi, with ±0.001 in. repeatability.
- The grip range is 0 to 4.125 in., with a recommended part weight under 10 lb.
- It is rated to 2,000,000 actuations, with service recommended every 250,000 cycles.
- A high-force version delivers roughly four times the grip of the standard model, for heavier parts.
The CNC becomes the robot. For flat parts, a vacuum version holds parts on a suction cup instead of jaws.
Side by side

| Factor | Robot arm cell | In-machine spindle gripper |
|---|---|---|
| Floor space | Needs floor next to the machine, plus guarding | None; works inside the enclosure |
| What moves the part | The robot arm | The machine's own axes |
| Programming | Robot program plus CNC handshake | G-code plus M-codes |
| Gripper hardware cost | Gripper plus arm, base, and integration | Gripper from $1,379 |
| Other parts needed | Auto door, part tables, safety system | Automated vise or fixture, part staging inside the machine |
| Part size range | Wide; set by the arm and gripper | Limited by grip range and machine travel |
| One unit, many machines | Possible with the right layout | One gripper per machine |
| Spindle time during loading | Machine waits while the robot loads | Machine waits while it loads itself |
That last row is worth a second look. With either method, the spindle is not cutting while the part loads. A robot cell does gain one thing here: it can deburr, measure, or stage the next part while the machine cuts.
When a robot arm is still the right call
A spindle gripper is not the answer for every shop. A robot arm makes more sense when:
- Parts are heavy or large. Past the gripper's range or the machine's safe load, an arm or a pallet system fits better.
- One robot serves two machines. A shared cell can spread the cost.
- Secondary work needs to happen. Deburring, washing, gauging, or laser marking between ops all favor an arm.
- Parts arrive mixed in bins. Vision-guided bin picking is robot work.
- The machine is a lathe without a suitable spindle setup. Many lathe tending jobs still go to a robot or a bar feeder.
For small and mid-size parts on a vertical machining center, the math often favors the spindle gripper. It costs less, takes no floor space, and stays inside the code your machinists already write. For the full picture on loading strategies, see our guide to CNC machine tending.
Robot Gripper FAQs
What are grippers in robotics?
Grippers are the end effectors that let a robot grasp, hold, and release objects. They mount to the robot's tool flange and use air, electric motors, vacuum, hydraulics, or magnets to hold parts. They are the only part of the robot that touches the workpiece.
Which robot gripper is best?
The best robot gripper depends on the part. Pneumatic parallel grippers are the best fit for most metal parts in machine tending and pick and place. Electric grippers win when parts vary and force must be controlled. Vacuum grippers win on flat, smooth parts, and soft grippers win on food and fragile items.
How much does a robot gripper cost?
Hobby kits cost about $9 to $85. Industrial pneumatic and electric grippers usually list from about $2,800 to $8,400, and multi-finger servo hands can pass $30,000. In-machine CNC spindle grippers start at $1,379 and need no robot arm.
What are the disadvantages of magnetic grippers?
Magnetic grippers only hold ferrous metals like steel and iron. Parts can keep residual magnetism and attract chips. Thin sheets can stick together, causing double picks. In machine shops, the magnet also collects chips from the work area.
Is a pneumatic or electric gripper better?
Pneumatic grippers are faster, stronger for their size, and cheaper. Electric grippers offer programmable force and position and need no air supply. For CNC machine tending, pneumatic is the common choice because machines already have shop air or through-spindle air.
How much grip force do I need?
For a friction grip, plan on 10 to 20 times the part weight for normal moves. Plan on 30 to 50 times for fast acceleration or impact. A 4 lb part needs about 40 to 80 lbf at normal speed. Fingers shaped to cradle the part reduce the force you need.
What is the difference between a gripper and an end effector?
An end effector is any tool on the end of a robot arm, such as a welding torch, a spray gun, or a gripper. A gripper is the type of end effector that holds parts. Every gripper is an end effector, but not every end effector is a gripper.
Can a CNC machine load its own parts without a robot arm?
Yes. A spindle gripper sits in the tool changer and uses the machine's axes to pick up blanks and load them into an automated vise. It is controlled by M-codes in the G-code program, so no robot or robot programming is needed.
Explore AI Summary